Loading...
Searching...
No Matches
utility::event::PalmEvent Class Reference
Palm pose event. More...
#include <headers/utility/event/palm_event.hpp>
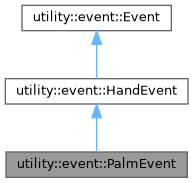
Inheritance diagram for utility::event::PalmEvent:
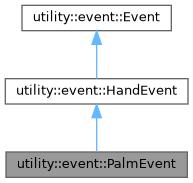
Collaboration diagram for utility::event::PalmEvent:
Classes | |
| class | Factory |
| Factory for creating PalmEvent instances. More... | |
Public Member Functions | |
| PalmEvent (void) | |
| Default constructor. | |
| ~PalmEvent (void) override | |
| Default destructor. | |
 Public Member Functions inherited from utility::event::HandEvent | |
| HandEvent (void) | |
| Default constructor. | |
| virtual | ~HandEvent (void) override |
| Default destructor. | |
| HandEvent & | setHandType (const HandType handType) noexcept |
| Set the type of hand involved in the event. | |
| HandType | getHandType (void) const noexcept |
| Get the type of hand involved in the event. | |
| HandEvent & | setPose (const graphic::PoseF &pose) noexcept |
| Set the pose of the hand. | |
| graphic::PoseF | getPose (void) const noexcept |
| Get the pose of the hand. | |
| HandEvent & | setAim (const graphic::PoseF &aim) noexcept |
| Set aim pose. | |
| graphic::PoseF | getAim (void) const noexcept |
| Get aim pose. | |
| HandEvent & | setGrip (const graphic::PoseF &grip) noexcept |
| Set grip pose. | |
| graphic::PoseF | getGrip (void) const noexcept |
| Get grip pose. | |
| HandEvent & | setGripSurface (const graphic::PoseF &gripSurface) noexcept |
| Set grip_surface pose. | |
| graphic::PoseF | getGripSurface (void) const noexcept |
| Get grip_surface pose. | |
| Public Member Functions inherited from utility::event::Event | |
| Event (void)=default | |
| Default constructor. | |
| virtual | ~Event (void)=default |
| Virtual destructor. | |
Additional Inherited Members | |
| Public Types inherited from utility::event::HandEvent | |
| enum class | HandType { Unknown = 0 , Left = 1 , Right = 2 } |
| Hand types for hand events. Defines the type of hand involved in the event (e.g., left or right). More... | |
Detailed Description
Palm pose event.
Definition at line 35 of file palm_event.hpp.
The documentation for this class was generated from the following files:
- headers/utility/event/palm_event.hpp
- sources/event/palm_event.cpp
