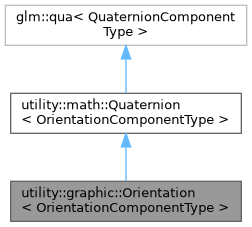
Represents the current 3D orientation (pose) of an object or view. More...
#include <headers/utility/graphic/orientation.hpp>
Public Member Functions | |
| Orientation (void) | |
| Default constructor (identity orientation). | |
| Orientation (OrientationComponentType value) | |
| Construct by filling all components with the same OrientationComponentType value. | |
| Orientation (const utility::math::Quaternion< OrientationComponentType > &quaternion) | |
| Construct from a quaternion. | |
| Orientation (OrientationComponentType x, OrientationComponentType y, OrientationComponentType z, OrientationComponentType w) | |
| Construct from explicit quaternion components (xyzw order). | |
| Orientation (std::initializer_list< OrientationComponentType > values) | |
| Construct from initializer list of three PositionComponentType values. | |
| Orientation (const std::initializer_list< OrientationComponentType > &value) | |
| Construct from a const initializer list of three PositionComponentType values. | |
| Orientation (const Orientation &other)=default | |
| Copy constructor. | |
| Orientation (Orientation &&other) noexcept=default | |
| Move constructor. | |
| Orientation & | operator= (const Orientation &other)=default |
| Copy assignment operator. | |
| Orientation & | operator= (Orientation &&other) noexcept=default |
| Move assignment operator. | |
| ~Orientation (void)=default | |
| Default destructor for Orientation. | |
| utility::math::Vector< OrientationComponentType, 3 > | getForward (void) const noexcept |
| Get the forward (Z-) axis in world space. | |
| utility::math::Vector< OrientationComponentType, 3 > | getUp (void) const noexcept |
| Get the up (Y+) axis in world space. | |
| utility::math::Vector< OrientationComponentType, 3 > | getRight (void) const noexcept |
| Get the right (X+) axis in world space. | |
| utility::math::Vector< OrientationComponentType, 3 > | transformPoint (const utility::math::Vector< OrientationComponentType, 3 > &local) const noexcept |
| Transform a point from local to world space. | |
| utility::math::Vector< OrientationComponentType, 3 > | rotateVector (const utility::math::Vector< OrientationComponentType, 3 > &direction) const noexcept |
| Rotate a direction vector by this orientation. | |
| Orientation | combined (const Orientation &parent) const noexcept |
| Combine with another orientation (parent * this). | |
| math::Matrix4x4F | toRotationMatrix (void) const noexcept |
| Convert the orientation to a 4x4 rotation matrix. | |
| Orientation | normalized (void) const noexcept |
| Return a normalized orientation. | |
| Orientation | inversed (void) const noexcept |
| Return inverse orientation. | |
| bool | isIdentity (OrientationComponentType epsilon=OrientationComponentType { 1e-6 }) const noexcept |
| Check whether this is approximately the identity orientation. | |
| bool | operator== (const Orientation &other) const noexcept |
| Equality operator for Orientation. | |
| bool | operator!= (const Orientation &other) const noexcept |
| Inequality operator for Orientation. | |
| bool | operator< (const Orientation &other) const noexcept |
| Less-than operator for Orientation. | |
 Public Member Functions inherited from utility::math::Quaternion< OrientationComponentType > | |
| Quaternion () | |
| Default constructor (identity quaternion). | |
| Quaternion (QuaternionComponentType x, QuaternionComponentType y, QuaternionComponentType z, QuaternionComponentType w) | |
| Construct from explicit components in (x, y, z, w) order. | |
| Quaternion (const glm::qua< QuaternionComponentType > &q) | |
| Construct from a GLM quaternion. | |
| Quaternion (const Quaternion &other)=default | |
| Copy constructor. | |
| Quaternion (Quaternion &&other) noexcept=default | |
| Move constructor. | |
| ~Quaternion ()=default | |
| Default destructor for Quaternion. | |
| Quaternion & | operator= (const Quaternion &other)=default |
| Copy assignment operator. | |
| Quaternion & | operator= (Quaternion &&other) noexcept=default |
| Move assignment operator. | |
| Quaternion | operator+ (const Quaternion &rhs) const noexcept |
| Quaternion addition. | |
| Quaternion & | operator+= (const Quaternion &rhs) noexcept |
| Quaternion addition assignment. | |
| Quaternion | operator- (const Quaternion &rhs) const noexcept |
| Quaternion subtraction. | |
| Quaternion | operator- (void) const noexcept |
| Unary negation. | |
| Quaternion & | operator-= (const Quaternion &rhs) noexcept |
| Quaternion subtraction assignment. | |
| Quaternion | operator* (const Quaternion &rhs) const noexcept |
| Quaternion multiplication (Hamilton product). | |
| Quaternion | operator* (QuaternionComponentType scalar) const noexcept |
| Scalar multiplication. | |
| Quaternion & | operator*= (const Quaternion &rhs) noexcept |
| Quaternion multiplication assignment (Hamilton product). | |
| Quaternion & | operator*= (QuaternionComponentType scalar) noexcept |
| Scalar multiplication assignment. | |
| bool | operator== (const Quaternion &rhs) const noexcept |
| Equality comparison. | |
| bool | equalsEpsilon (const Quaternion &rhs, QuaternionComponentType epsilon=QuaternionComponentType { 1e-5 }) const |
| Approximate equality using an epsilon threshold. | |
| bool | operator!= (const Quaternion &rhs) const noexcept |
| Inequality comparison. | |
Detailed Description
class utility::graphic::Orientation< OrientationComponentType >
Represents the current 3D orientation (pose) of an object or view.
- Template Parameters
-
OrientationComponentType Floating-point type for quaternion components.
- Note
- An orientation describes how the object is rotated in space relative to a reference frame (e.g. world or parent), but does not describe the history of how it got there.
Definition at line 53 of file orientation.hpp.
Constructor & Destructor Documentation
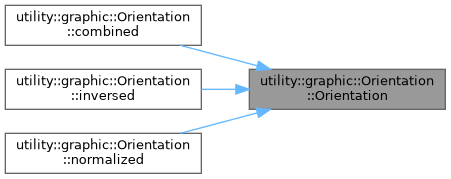
◆ Orientation() [1/8]
|
inline |
Default constructor (identity orientation).
- Note
- Initializes to no rotation (facing -Z, up +Y).
Definition at line 62 of file orientation.hpp.
◆ Orientation() [2/8]
|
inlineexplicit |
Construct by filling all components with the same OrientationComponentType value.
- Parameters
-
value The OrientationComponentType value to fill all components with.
Definition at line 75 of file orientation.hpp.
◆ Orientation() [3/8]
|
inlineexplicit |
Construct from a quaternion.
- Parameters
-
quaternion Quaternion to use for orientation.
Definition at line 85 of file orientation.hpp.
◆ Orientation() [4/8]
|
inline |
Construct from explicit quaternion components (xyzw order).
- Parameters
-
x X component. y Y component. z Z component. w W component.
Definition at line 99 of file orientation.hpp.
◆ Orientation() [5/8]
|
inline |
Construct from initializer list of three PositionComponentType values.
- Parameters
-
values The initializer list containing x, y, z components.
- Exceptions
-
std::invalid_argument if the list size is not 3.
Definition at line 111 of file orientation.hpp.
◆ Orientation() [6/8]
|
inline |
Construct from a const initializer list of three PositionComponentType values.
- Parameters
-
value Source vector.
Definition at line 132 of file orientation.hpp.
◆ Orientation() [7/8]
|
default |
Copy constructor.
- Parameters
-
other The Orientation object to copy from.
◆ Orientation() [8/8]
|
defaultnoexcept |
Move constructor.
- Parameters
-
other The Orientation object to move from.
Member Function Documentation
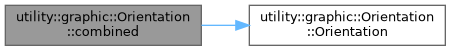
◆ combined()
|
inlinenoexcept |
Combine with another orientation (parent * this).
- Parameters
-
parent Parent orientation to combine with.
- Returns
- Combined orientation (parent * this).
Definition at line 246 of file orientation.hpp.
◆ getForward()
|
inlinenoexcept |
Get the forward (Z-) axis in world space.
- Returns
- Forward direction as a 3D vector.
Definition at line 174 of file orientation.hpp.
◆ getRight()
|
inlinenoexcept |
Get the right (X+) axis in world space.
- Returns
- Right direction as a 3D vector.
Definition at line 204 of file orientation.hpp.
◆ getUp()
|
inlinenoexcept |
Get the up (Y+) axis in world space.
- Returns
- Up direction as a 3D vector.
Definition at line 189 of file orientation.hpp.
◆ inversed()
|
inlinenoexcept |
Return inverse orientation.
- Returns
- Inverse quaternion orientation.
Definition at line 288 of file orientation.hpp.
◆ isIdentity()
|
inlinenoexcept |
Check whether this is approximately the identity orientation.
- Parameters
-
epsilon Absolute tolerance for each component.
- Returns
- True when x,y,z are near 0 and w is near 1.
Definition at line 302 of file orientation.hpp.
◆ normalized()
|
inlinenoexcept |
Return a normalized orientation.
- Returns
- Orientation with unit quaternion length.
Definition at line 275 of file orientation.hpp.
◆ operator!=()
|
inlinenoexcept |
Inequality operator for Orientation.
- Parameters
-
other The other Orientation to compare with.
- Returns
- True if the orientations are not equal, false otherwise.
Definition at line 338 of file orientation.hpp.
◆ operator<()
|
inlinenoexcept |
Less-than operator for Orientation.
- Parameters
-
other The other Orientation to compare with.
- Returns
- True if this orientation is less than the other, false otherwise.
Definition at line 349 of file orientation.hpp.
◆ operator=() [1/2]
|
default |
Copy assignment operator.
- Parameters
-
other The Orientation object to copy from.
- Returns
- A reference to this Orientation object.
◆ operator=() [2/2]
|
defaultnoexcept |
Move assignment operator.
- Parameters
-
other The Orientation object to move from.
- Returns
- A reference to this Orientation object.
◆ operator==()
|
inlinenoexcept |
Equality operator for Orientation.
- Parameters
-
other The other Orientation to compare with.
- Returns
- True if the orientations are equal, false otherwise.
Definition at line 316 of file orientation.hpp.
◆ rotateVector()
|
inlinenoexcept |
Rotate a direction vector by this orientation.
- Parameters
-
direction Direction in local space.
- Returns
- Rotated direction in world space.
Definition at line 234 of file orientation.hpp.
◆ toRotationMatrix()
|
inlinenoexcept |
Convert the orientation to a 4x4 rotation matrix.
- Returns
- Rotation matrix corresponding to this orientation.
- Note
- The resulting matrix can be used for transforming vertices or constructing view matrices, but does not include translation or scaling components. It represents only the rotation defined by the quaternion.
Definition at line 264 of file orientation.hpp.
◆ transformPoint()
|
inlinenoexcept |
Transform a point from local to world space.
- Parameters
-
local Point in local space.
- Returns
- Transformed point in world space.
Definition at line 219 of file orientation.hpp.
The documentation for this class was generated from the following file:
- headers/utility/graphic/orientation.hpp
